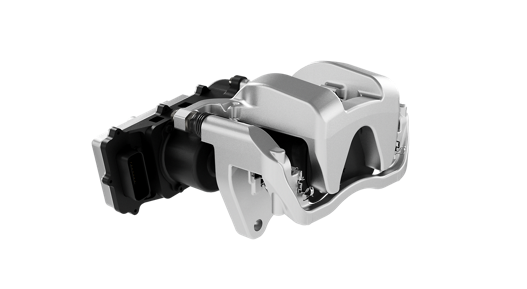
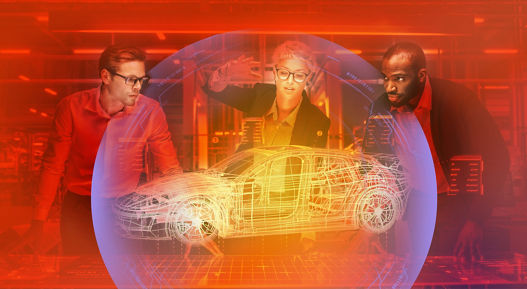
3D visualization of an electric vehicle chassis with transparent body structure. Key components such as brakes, suspension, steering, and powertrain are highlighted in glowing orange. At the center, a high-performance computer is represented by a purple energy effect, symbolizing holistic motion control for advanced vehicle dynamics.

Holistic motion control system

Motion control software platform for assisted-, autonomous-, and manual driving use cases with integrated safety and stability.

Software-defined vehicle (SDV) defines vehicles with features and functions that are primarily enabled by software. In the future, new functions can thus be activated individually according to the driver's needs. Examples are temporary services, functions or apps. Software updates therefore enable contract and pricing models in which new functions are offered as a service. As a subscription or for individual purchase.

The vehicle can communicate with its environment, collect data during real operation and send it to the cloud. Based on this data, functions and services can be continuously improved and loaded into the vehicle via over-the-air updates (OTA).


Trends such as electrification, automation, and connectivity are primarily enabled by software. Many drivers expect the vehicle to be fully integrated into their digital world. As with a smartphone, for example, new functions should constantly be available for their vehicle. This challenge also holds opportunities: With regular updates, the value of the vehicle over its entire life cycle can not only be maintained, but also increased.

Detailed graphic of an electric vehicle chassis with labeled components: Suspension, Steering, Brakes, and Powertrain. A glowing purple effect in the center represents the high-performance computer enabling holistic motion control. The interface includes side panels with images of scenic roads and autonomous driving, emphasizing system capabilities and driving experience.

Historically, in distributed vehicle architectures the individual driving function was closely coupled to the motion actuators in the vehicle. In future architectures a unified building block, actuator agnostic is decoupling the driving function from the specific actuator and vehicle setup. This command center to orchestrate all vehicle motion actuators for longitudinal, lateral, and vertical control is our holistic motion control.

Do you want to know more?

*If the contact form does not load, please check the advanced cookie settings and activate the functional cookies for the purpose of contact management.